NOLO Non-Line-of-Sight Teleoperation

Embodied AI · Non-Line-of-Sight Teleoperation

Non-line-of-sight teleoperation
first-person remote operation

A cloud-rendered communication link: teleoperation commands flow down, first-person video flows up. Put on a NOLO headset, look through the robot's stereo cameras, and drive the robot to perform fine work — shelf restocking, sales, assembly, inspection, maintenance and care — from across a wall, a floor or a city. Head-and-hand 6DoF pose is solved in 2ms, with end-to-end average latency of about 70ms on a LAN.

Cloud-Rendered Link Head & Hand 6DoF Pose Sub-Millimeter Tracking
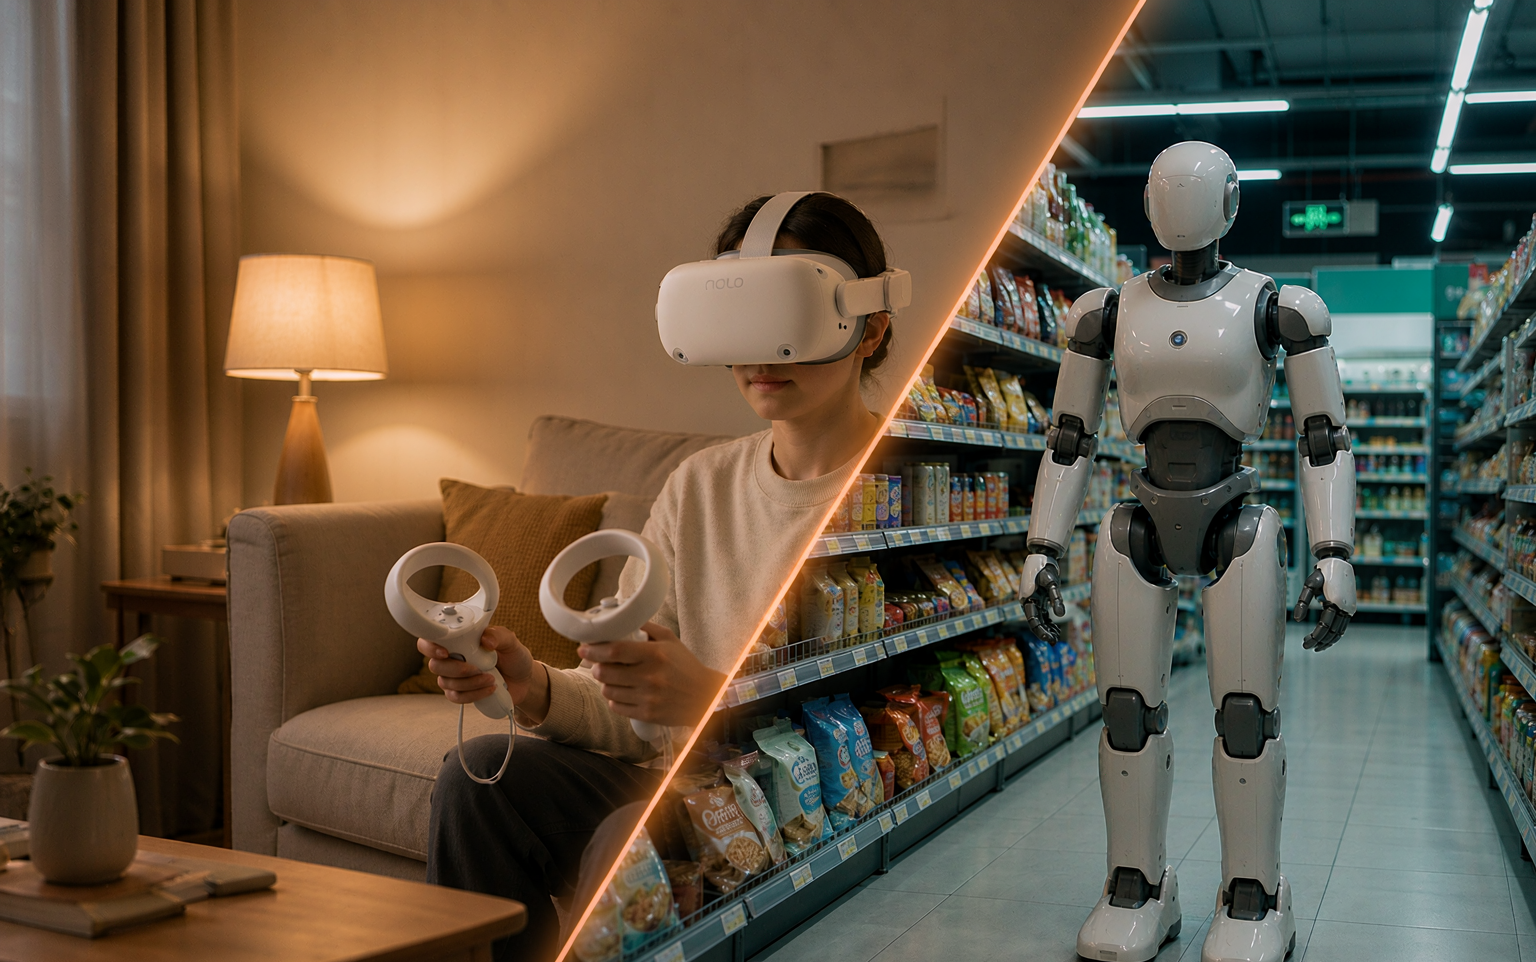
Operator wearing a NOLO VR headset with motion controllers teleoperating a robot
Control the robot remotely, right from home
4KUltra HDRecommended resolution, robot stereo module
~70msEnd-to-end average latency, measured on LAN
2msHead-and-hand 6DoF capture & processing

Operate precisely without seeing the robot.
Freeing teleoperation from “on-site line of sight” to “any distance”.

Conventional teleoperation requires the operator and the robot to share the same line of sight. NOLO's non-line-of-sight teleoperation is built on a first-person video stream and millimeter-level head-and-hand pose: put on a headset and you “become the robot” — driving it through real work such as shelf restocking, sales, assembly, inspection, maintenance and care from across a wall, a floor or a city. It is about getting the job done, not about collecting data.

01

Line-of-Sight Constraint

Conventional teleoperation relies on the operator looking directly at the robot — cross a wall, a floor or a city and it stops working. Every deployment has to be designed around “being able to see”.

02

Latency Stacks Up

Capture, encoding, transmission, decoding, display, feedback — delay in any single stage collapses the “feel” of remote control.

NOLO SOLUTION

A cloud-rendered link that brings the site to your eyes

The robot's stereo module streams a first-person stereo view to the operator's headset in real time; head-and-hand 6DoF pose is solved by our in-house StarTraq® sub-millimeter tracking, strictly synchronized with the video and sent over the network to the robot. Controller actions are mapped to robot commands in real time through sub-millimeter tracking — what you see is what you reach, and what you move is what arrives.

  • Teleoperation commands down, perception data up — one cloud-rendered link, closed loop
  • Head-and-hand 6DoF pose captured and processed in 2ms, strictly time-aligned with video frames
CORE CAPABILITIES

Millisecond-level latency — the capability base for non-line-of-sight teleoperation

Sub-Millimeter Pose Tracking

In-house StarTraq® positioning holds sub-millimeter accuracy and millisecond-level latency in complex real environments — the robot goes exactly where you aim.

<1mm accuracy | <5ms latency | 250Hz refresh

2ms Head-and-Hand 6DoF

Head and both hands are solved per frame with just 2ms of capture and processing, strictly time-aligned with video frames — commands and motion stay in sync at millisecond level.

2ms capture & processing | strictly synced with video

Pose Prediction Lead Time

Future motion is predicted from the current data stream, compensating delay introduced by the network and display chain for smooth, drift-free control.

<11ms lead time | smooth, no drift

First-Person Stereo Display

The robot's stereo module streams a first-person stereo view to the headset, restoring true depth perception — a full sense of presence from a thousand miles away.

4K Ultra HD

Dexterous Controller Interaction

Motion controllers are tracked by StarTraq® at sub-millimeter precision; 6DoF pose is regenerated frame by frame, and button and trigger actions map to robot commands in real time — precise grasping, aimed exactly where you point.

Sub-millimeter tracking | real-time action mapping
SPECIFICATIONS

Core Specifications

Video & Display Recommendations

VIDEO & OPTICS
Robot Stereo ModuleResolution no lower than 4K Ultra HD (combined stereo)
Video LinkImage capture & encoding → network transmission → terminal decoding → screen presentation
Screen PresentationDisplay interval approx. 11ms (set by frame rate)
Terminal DecodingVideo decode latency approx. 8ms
Communication LinkA cloud-rendered link: teleoperation commands down, perception data up

Pose & Tracking Metrics

TRACKING & CONTROL
PositioningStarTraq® (acoustic-optical-RF and visual-inertial fused tracking)
Pose Accuracy<1mm accuracy, <5ms latency, 250Hz refresh rate
Head-and-Hand 6DoFCapture and processing in 2ms, strictly synchronized with video frames
Pose PredictionLead time <11ms, predicting future motion from current data
Motion ControllersSub-millimeter 6DoF tracking of both hands; button and trigger actions map to control commands in real time

Make every remote task as reliable as being on site

Book a demo or discuss your non-line-of-sight teleoperation deployment with us. Based on your robot platform and network conditions, the NOLO team will advise on everything from hardware selection and link design to deployment tuning.

Business & Partnership